Humanoid Joint Hardware Stack Guide
Connect motors, reducers, bearings, encoders, brakes and packaging decisions inside humanoid joints.
- Motion & Actuation
- Humanoid Robots
- Joint Packaging
Robot Engineering Resources
Use practical guides, configuration tools and engineering documentation to define hardware requirements, compare options and prepare your robot project.
Learn • Compare • Select • Configure • Prepare
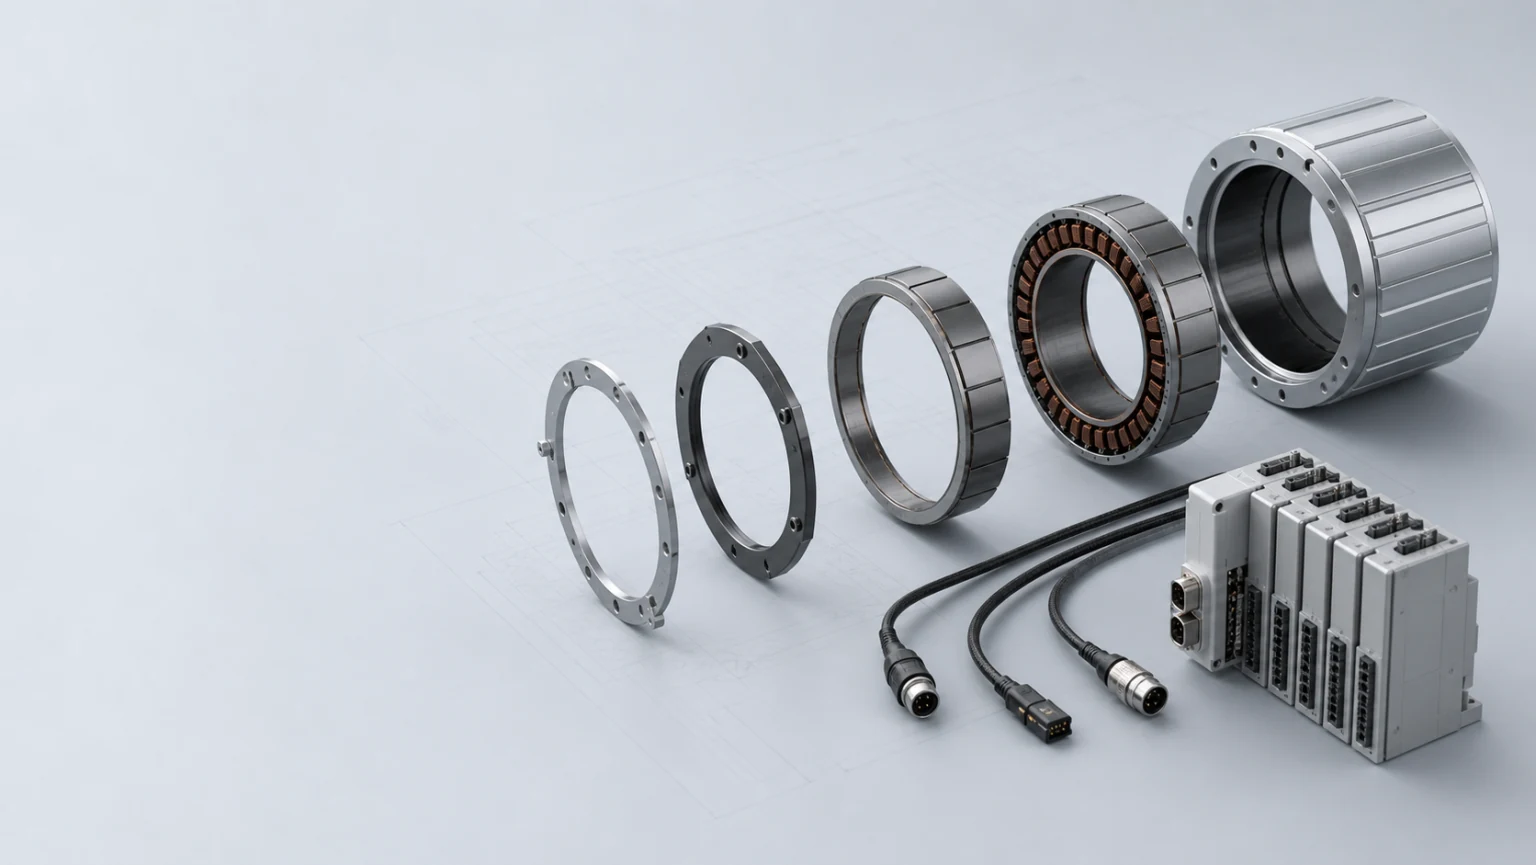
Reference-based conceptual engineering asset. Not a product drawing and not to scale.
What are you looking for?
Move directly to practical guidance, engineering documentation or an interactive selection task.
Featured Engineering Guides
Practical references for defining requirements, comparing approaches and preparing project information.
Connect motors, reducers, bearings, encoders, brakes and packaging decisions inside humanoid joints.
Plan connectors, pinouts, shielding, bend life, routing and serviceability for robot interconnects.
Plan camera, LiDAR, radar, trigger, bandwidth and mounting requirements across a robot sensing stack.
Configuration & Selection Tools
Use interactive tools to define requirements and narrow practical hardware options.
Engineering Files
Find available drawings, CAD, datasheets and interface documentation. Some project or supplier-sensitive files require request-based access.
Drawings · STEP/STP · Datasheets · Interface documentation
Put the resource to work
Choose a guide, tool or engineering file for the decision in front of you.
Capture the robot, subsystem, interfaces and known requirements that shape the choice.
Move into the relevant product, capability or custom request when you are ready.
Need help finding the right resource?
Share the robot, subsystem or hardware question you are working through, and we can point you toward the most relevant guide, tool or next step for your project.